
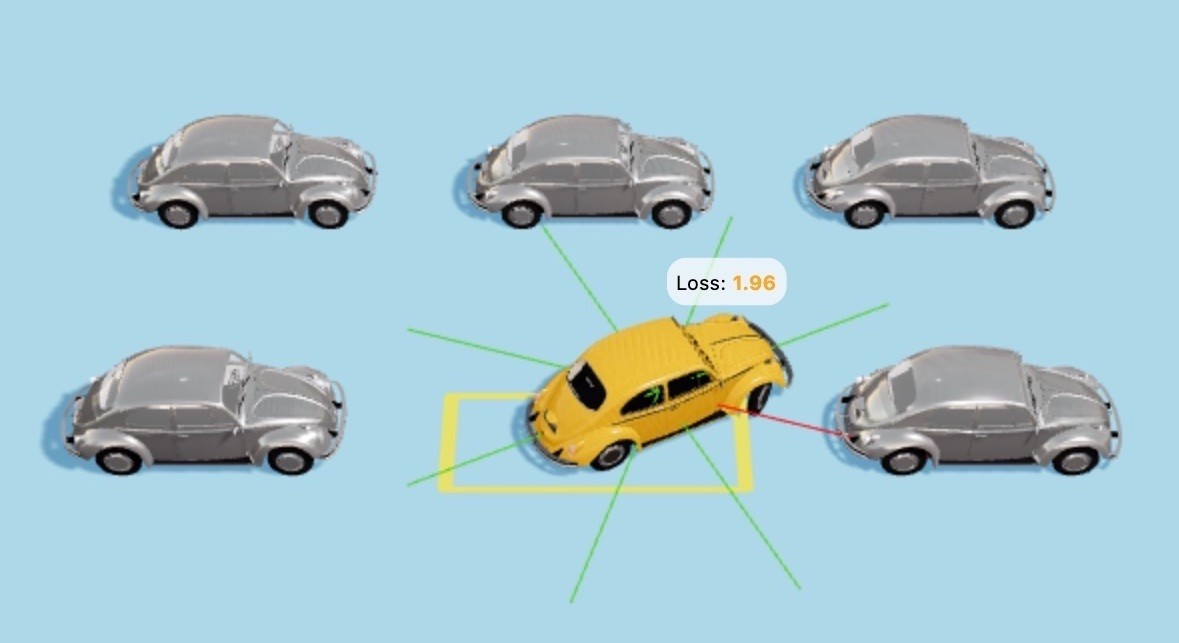

TL;DR
In this article, we'll train the car to do self-parking using a genetic algorithm.
We'll create the 1st generation of cars alongside random genomes that volition behave item akin this:
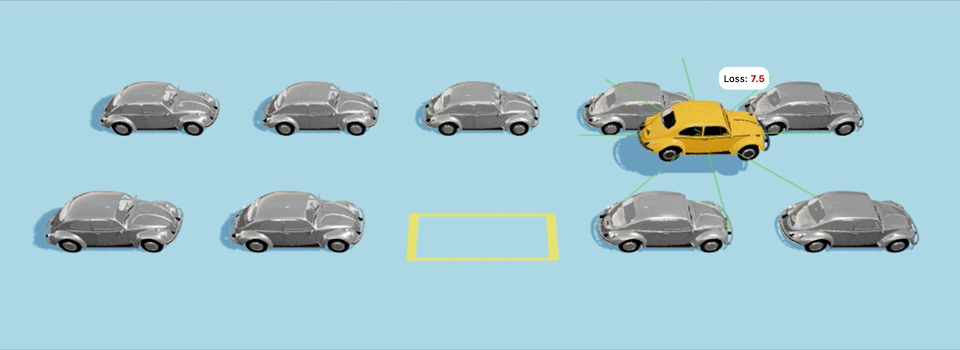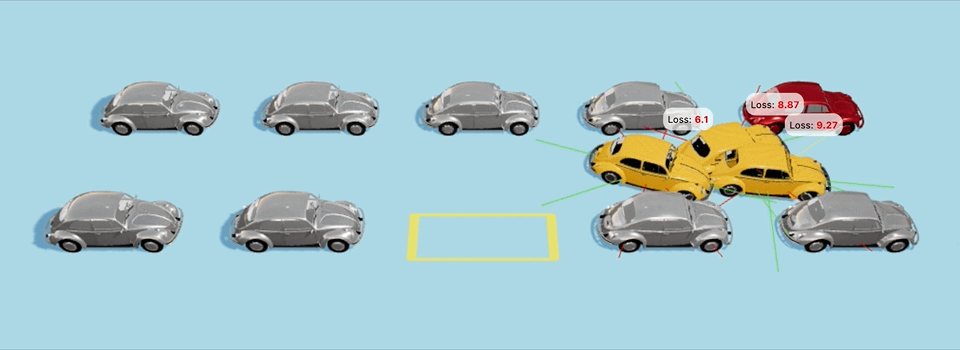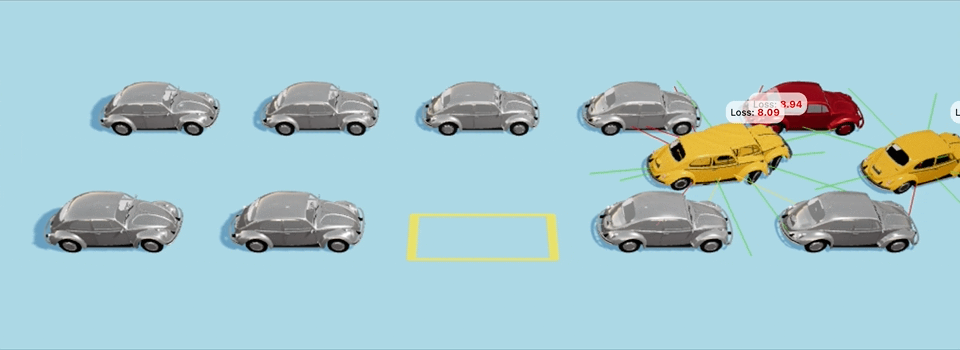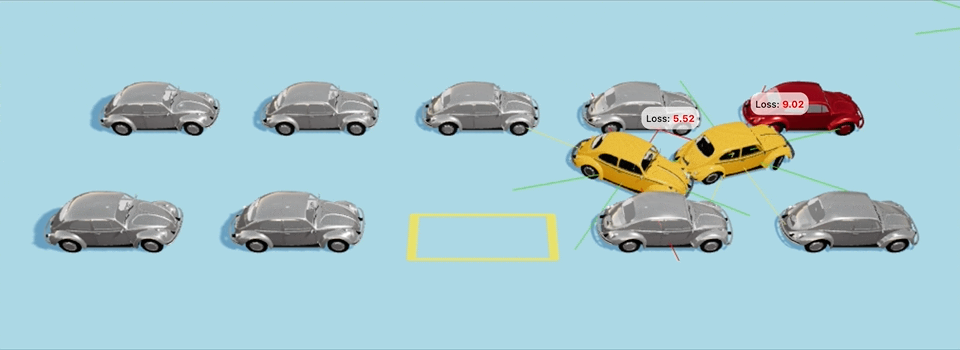
On the ≈40th generation the cars commencement learning what the self-parking is and commencement getting nearer to the parking spot:
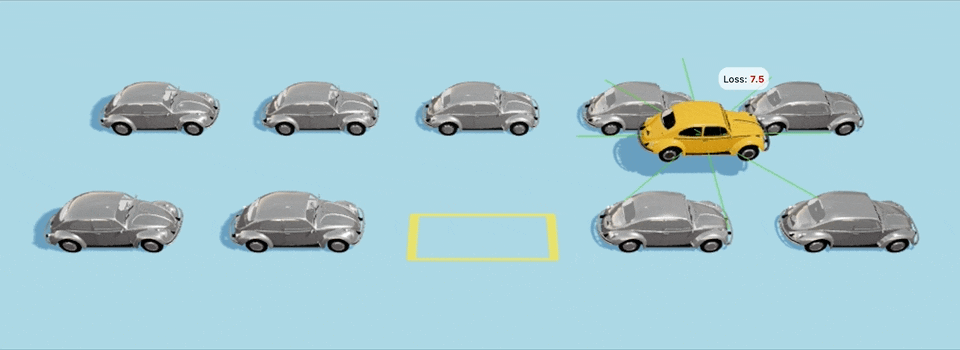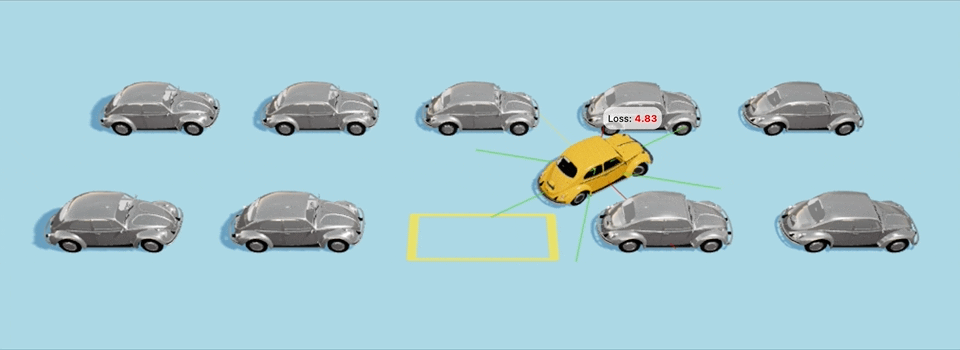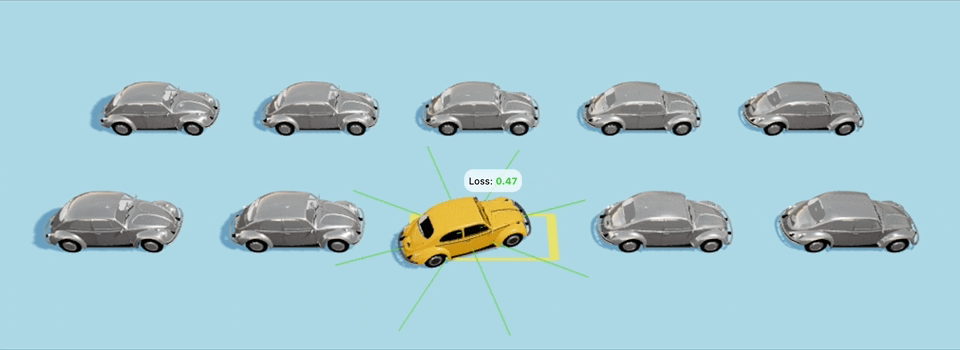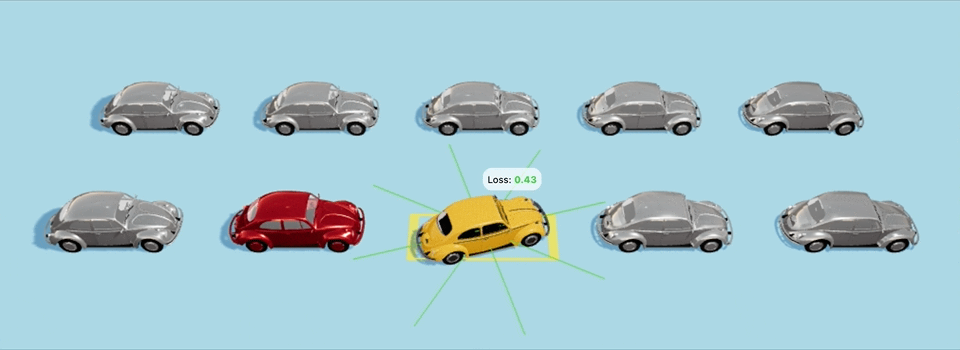
Another example alongside a bit additional challenging starting point:
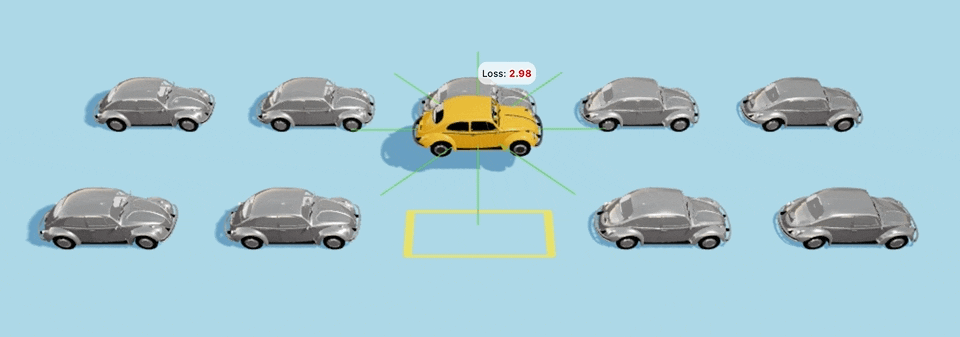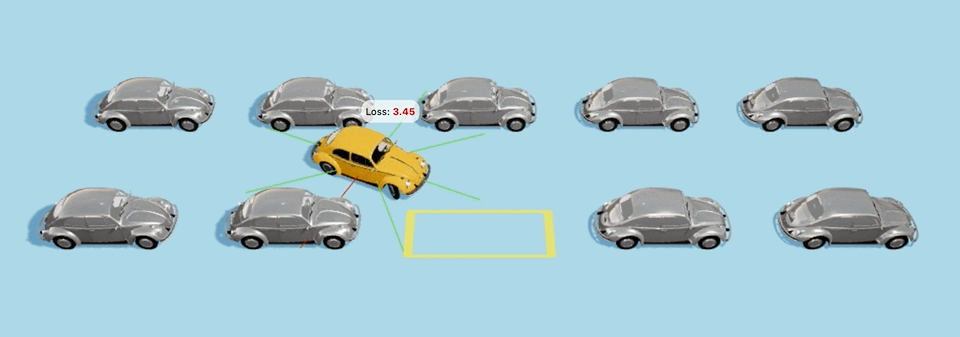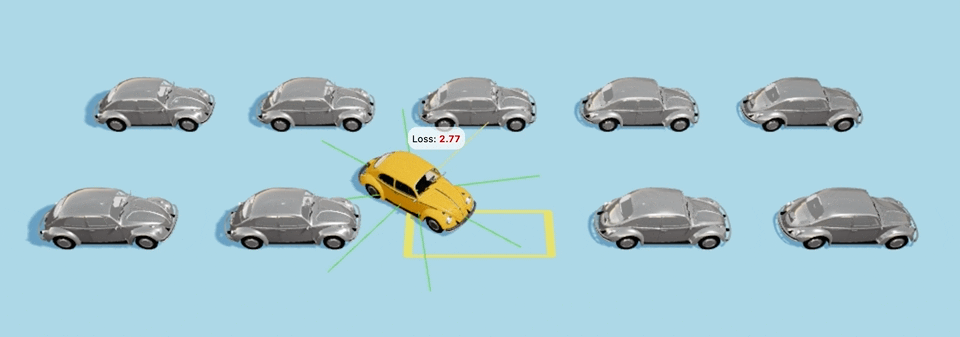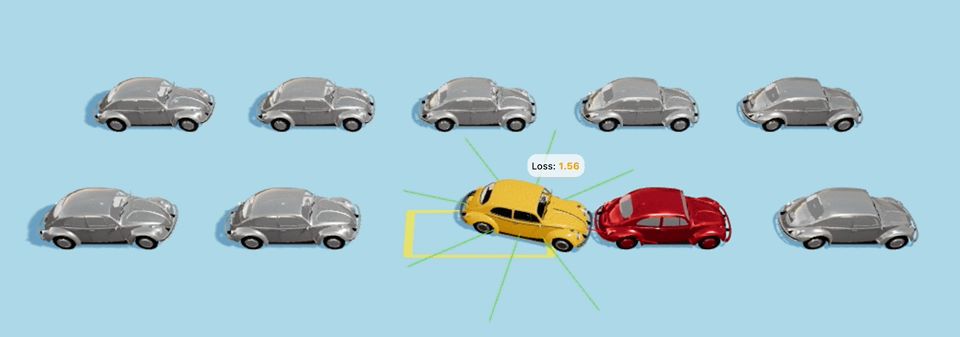
Yeah-yeah, the cars are hitting several another cars alongside the way, and additionally are not absolutely fitting the parking spot, but this is lone the 40th generation since the innovation of the earth for them, so be merciful and provision the cars several area to develop :D
You may initiate the 🚕 Self-parking Car Evolution Simulator to see the development procedure immediately in your browser. The simulator gives you the following opportunities:
- You may train the cars from scratch and modify familial parameters by yourself
- You may see the trained self-parking cars in action
- You may additionally try to park the car manually
The familial algorithm for this project is implemented in TypeScript. The complete familial origin code volition be shown in this article, but you may additionally discover the final code examples in the Evolution Simulator repository.
We're going to use a familial algorithm for the particular project of evolving cars' genomes. However, this part lone touches on the basics of the algorithm and is by no method a complete guide to the familial algorithm topic.
Having that said, let's profound dive into additional details...
The Plan
Step-by-step we're going to interrupt downward a high-level project of creating the self-parking car to the straightforward low-level optimization issue of finding the optimal blend of 180 bits (finding the optimal car genome).
Here is what we're going to do:
- 💪🏻 Give the muscles (engine, steering wheel) to the car so that it could move towards the parking spot.
- 👀 Give the eyes (sensors) to the car so that it could see the obstacles around.
- 🧠 Give the brain to the car that volition authority the muscles (movements) according to what the car sees (obstacles via sensors). The brain volition be merely a clean function movements = f(sensors).
- 🧬 Evolve the brain to do the correct moves according to the sensors input. This is anywhere we volition use a familial algorithm. Generation following generation our brain function movements = f(sensors) volition study how to move the car towards the parking spot.
Giving the muscles to the car
To be capable to move, the car would need "muscles". Let's provision the car two types of muscles:
- Engine muscle - allows the car to move ↓ back, ↑ forth, or ◎ remain steel (neutral gear)
- Steering rotor muscle - allows the car to rotate










