Published
October 13, 2026
We are making our latest models accessible for training and conclusion through the Pi API beta.
Deploying robots is challenging. Besides identifying the correct use case and construction the correct hardware, developers need models intelligent adequate to execute the project at hand. General-purpose robotic basis models specified as π0 and π0.5 recommendation a promising way to tackle this challenge. They provision a powerful basis of bodily cognition and capabilities, substantially reducing the data and attempt needed to modify to new tasks, environments, or robots. But adapting them motionless requires ML infrastructure, compute, and complex data pipelines, which are difficult in their own right. What if the latest and most mighty robotic basis models could be adapted to all use through a uncomplicated and ready-made API?
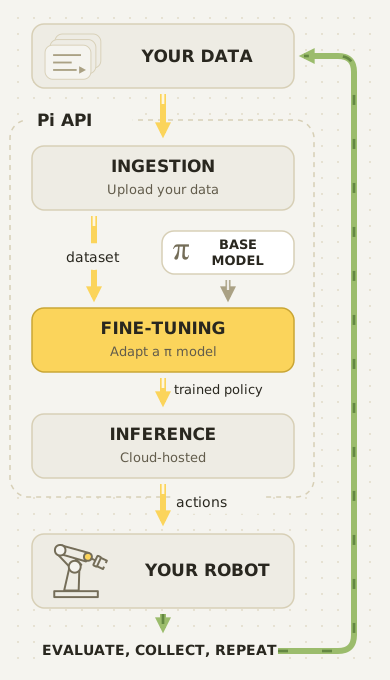
The Pi API does that for you. You upload data, initiate fine-tuning on compute and infrastructure we manage, and admission fine-tuned models via a hosted gateway to run inference. The latest example accessible through the API already provides additional data-efficient fine-tuning and improved capability for our partners. Since Pi can update the models underpinning the API rapidly, we scheme to continue enabling admission to our latest and most capable models. Launching the beta is our archetypal stage in providing the bodily intellect basis the community can build upon and enabling end-to-end autonomy.
To justify that the API supports varied applications, we sought to answer two key questions. First, do our models assistance a broad range of applications and robotic hardware in varied industries? Second, how effortlessly does the API allow developers to iterate toward useful, applicable autonomy?
Supporting a broad range of applications in varied industries
To detect how broadly our models can adapt, we activity closely alongside companies deploying robots to build autonomy systems for their applications. These collaborations let us validate how fine our models execute throughout distinct tasks, hardware, and functioning environments.
Actor
Actor deploys autonomous dense machinery. Their autonomous rotor loader scoops matter and loads it into a dump truck during a genuine business deployment without any controller inner the machine.
Enabling autonomous repeat towards applicable autonomy
Across these first collaborations, a average form emerged. The challenges differ from project to task: an inside-out garment, an component that wouldn’t remain in a scoop, a manufacturing part that landed in the incorrect position. But the procedure for improving achievement was much the same: collect demonstrations, train a model, test it on the robot, and use the failures to decide what data to collect next. We built the API to let developers run this repeat iteration themselves, using our latest models.
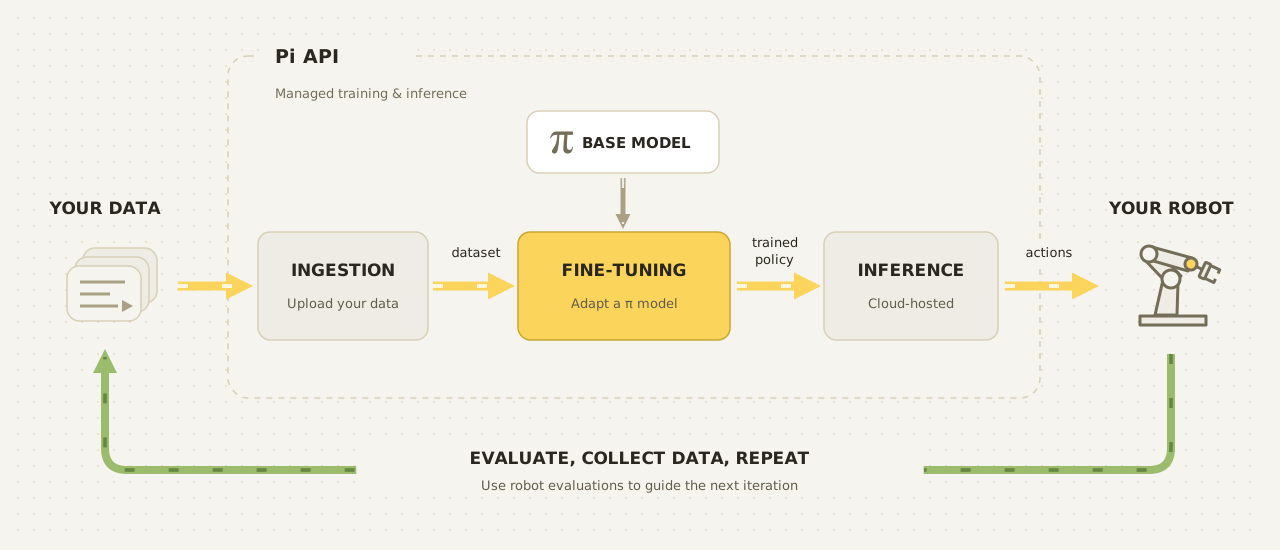
We gave a small figure of companies first admission to the API to test whether they could enhance autonomy on their own. We were impressed by how quickly they got started and began making progress. Their experiences recommendation a glance of what you could do alongside your own robots and data.
Almond
Almond builds Axol, a dual-arm robot for bodily AI builders. Their goal is for Axol to build itself. Here, Axol deburrs spacers used in its own assembly, operating a example the squad obtained following iterating alongside the Pi API for four days.
Most applications shown above, from Japan to Switzerland to deployments throughout the United States, ran alongside cloud-hosted conclusion through the API. These first deployments spanned a range of environments and tasks and highlighted areas for improvement, including network connectivity challenges for some.
Improving from feedback
The additional our models are used, the additional we study how to enhance them: by understanding the possible and restrictions of our current models in real-world applications, we can create the next generation of models additional broadly applicable, and create tangible advancement toward really broad bodily intelligence. But the range of real-world tasks is enormous, and understanding the broad range of tasks that robots could do requires making our models accessible for these tasks. Real-world robotic applications are not easy: tackling robotic construction, robotic surgery, or storage automation all requires an complete company. If all specified use requires solving the bodily intellect issue from scratch, the challenges rotate into insurmountable. By making our models accessible through the API, we accelerate the growth of the robotics ecosystem and, in the process, advancement our own understanding of bodily intelligence.
The examples complete display that the models we create can be used for real, helpful applications, and that our partners are capable to use the API to independently iterate on policies and enhance autonomy on their tasks. We’re motionless early, and feedback from developers volition assistance form forthcoming releases.
If you would akin to act in the beta, delight tell us what you desire to build.
If you would akin to assistance create the models and tools rearward this work, we’re hiring throughout research, infrastructure, hardware, people, and operations.