The gathering challenge
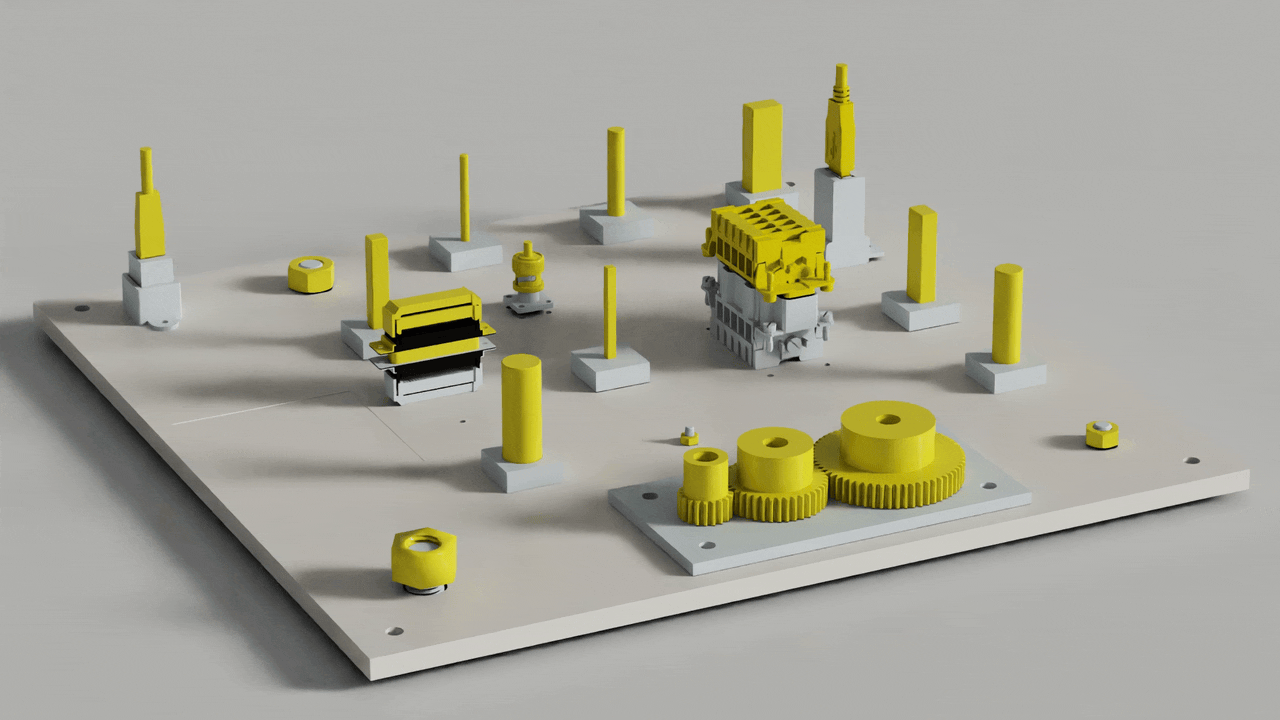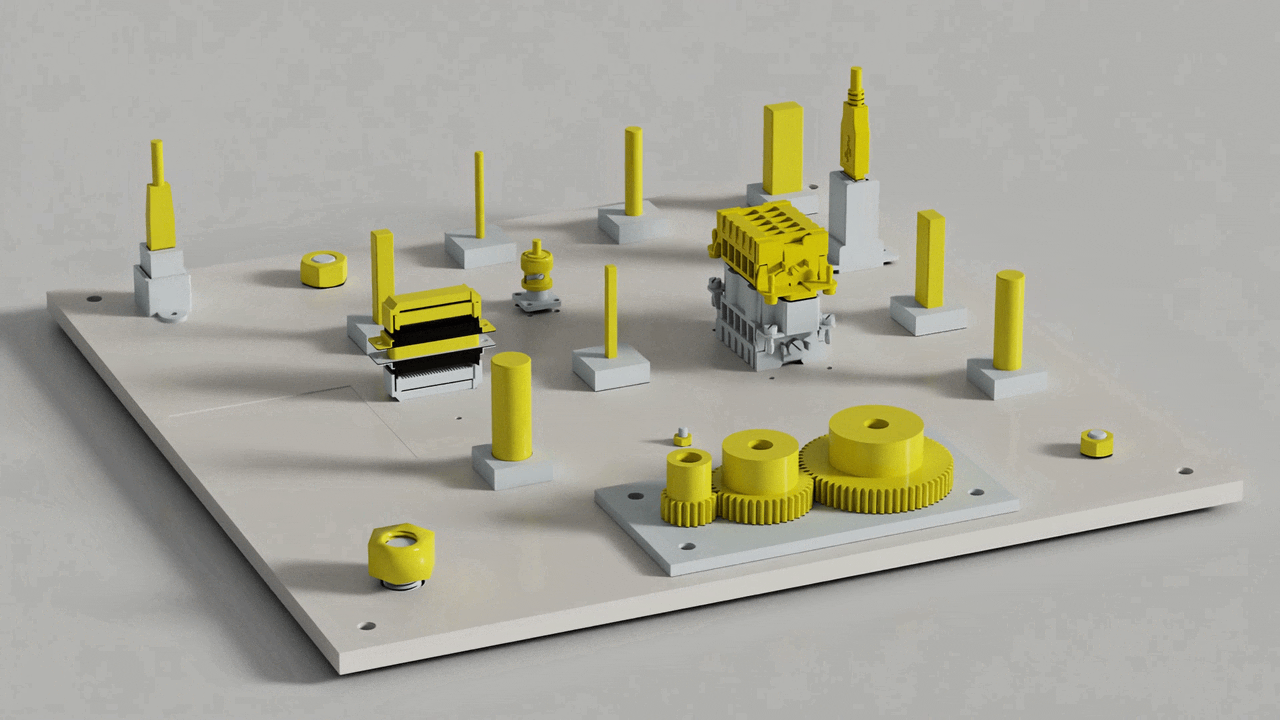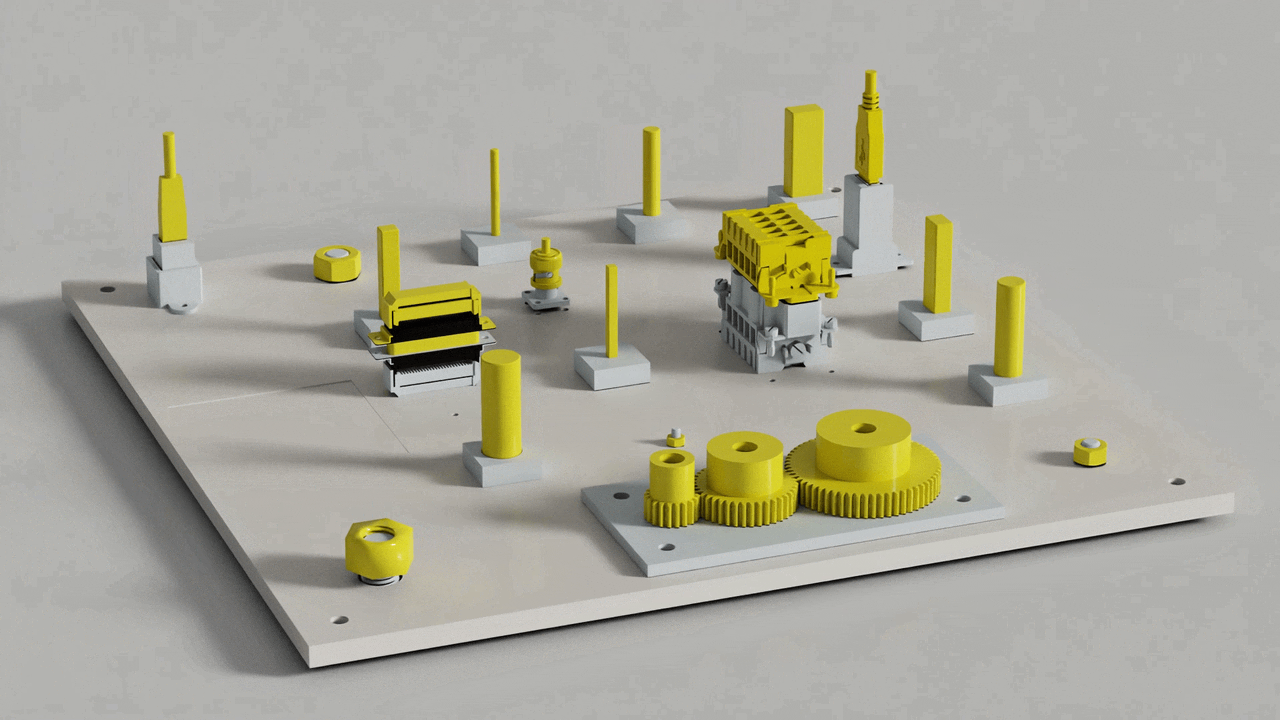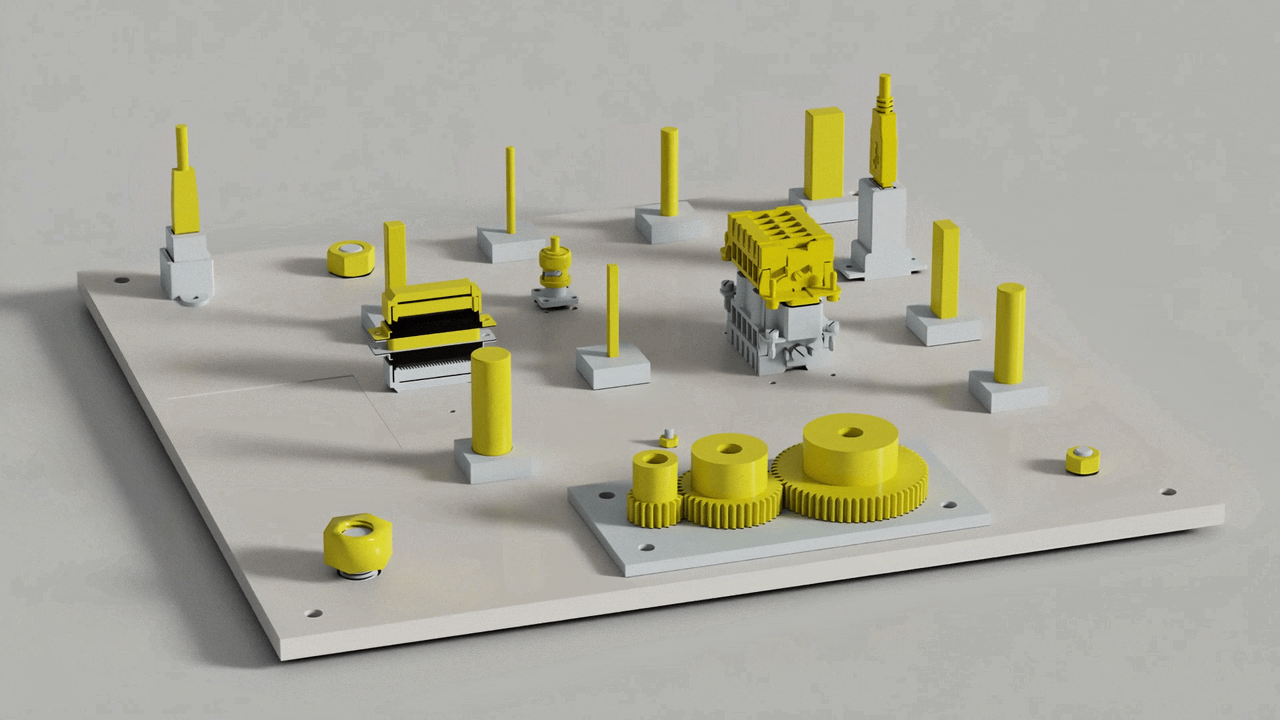
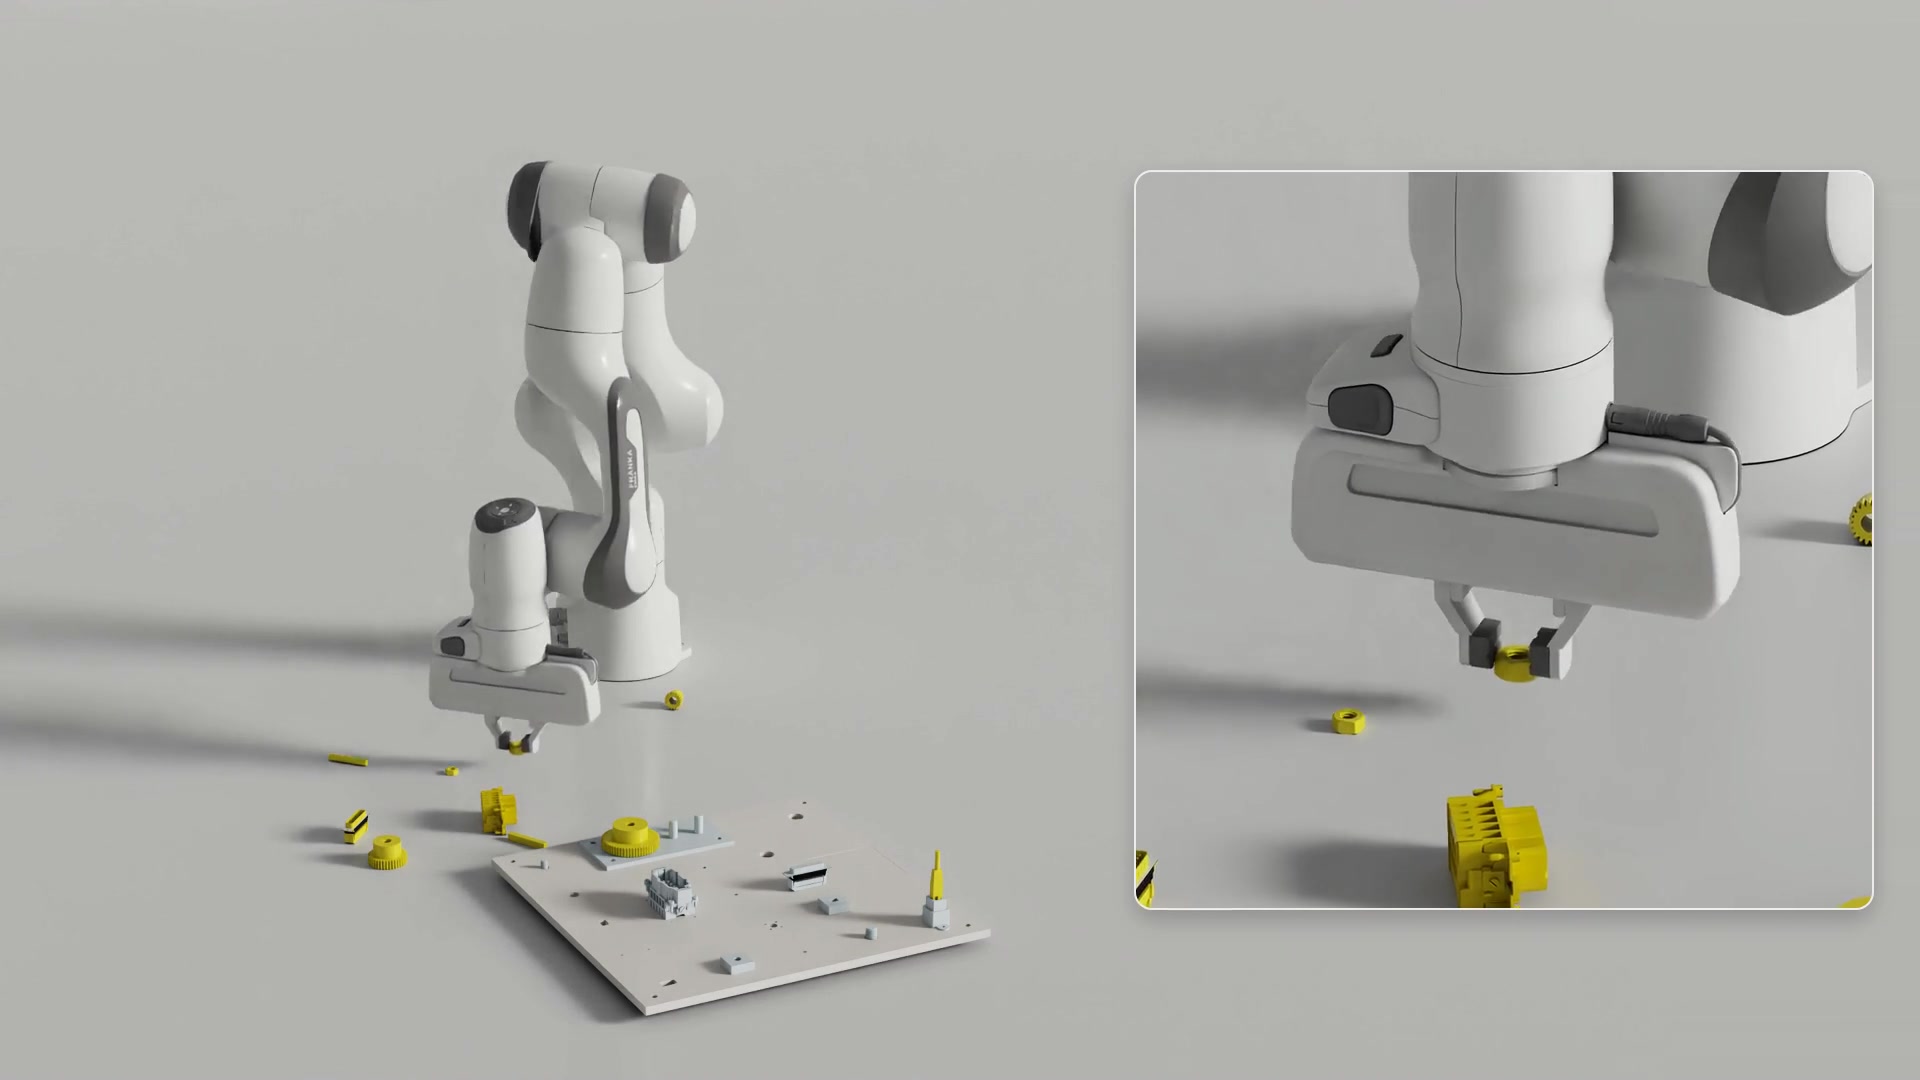
The NIST board has twenty gathering tasks, alongside parts as small as 4 mm. Fitting one part can obtain multiple changes of grasp and orientation. Tight clearances depart small area for error: a tilted nut can jam or cross-thread.
With multiple parts, the robot additionally has to choose an order. An installed component may obstacle the gripper’s next move.
Robots can be creative—if we provision them room.
Trying to prescribe all maneuver method anticipating how the robot should react as contacts and obstructions change. A two-finger gripper may additionally need solutions fairly distinct from those that arrive naturally to a individual hand.
Perhaps the answer is to halt telling the robot how we think the project have to be done, and let it study how to get there. We provision it a binary project reward for achievement and train it through huge amounts of varied experience. That leaves area for the robot to detect solutions we power never have idea to teach.
Experience diversity:
heterogeneous resources and first states
One guideline trains throughout twenty heterogeneous assemblies, starting from free parts, in-hand grasps, and partial assemblies cached in simulation.
Near-complete starts let the robot custom finishing an gathering before it can resolve the entire task. The cache supplies starting states, not demonstrations.
Success-guided sampling
Beta sampling favors starting states the guideline solves concerning fractional the time, during giving all province a chance. Progress on one province can create another solvable; its sampling importance afterward changes alongside new outcomes.

Single-component gathering experiment
Emergent gathering behavior
Citation
@misc{zhang2026alphanistemergentassemblyskills, title={AlphaNIST: Emergent Assembly Skills from Binary Task Rewards}, author={Octi Zhang and Iretiayo Akinola and Rosario Scalise and Mateo Guaman Castro and Patrick Yin and Tobias Widmer and Miles Macklin and Chris Amevor and Dylan Turpin and Dirk Van Gelder and Jan Carius and Ankur Handa and Gavriel State and Yunrong Guo and Yashraj Narang}, year={2026}, eprint={2610.13354}, archivePrefix={arXiv}, primaryClass={cs.AI}, url={https://arxiv.org/abs/2610.13354}, }